THANKS!
Previous |
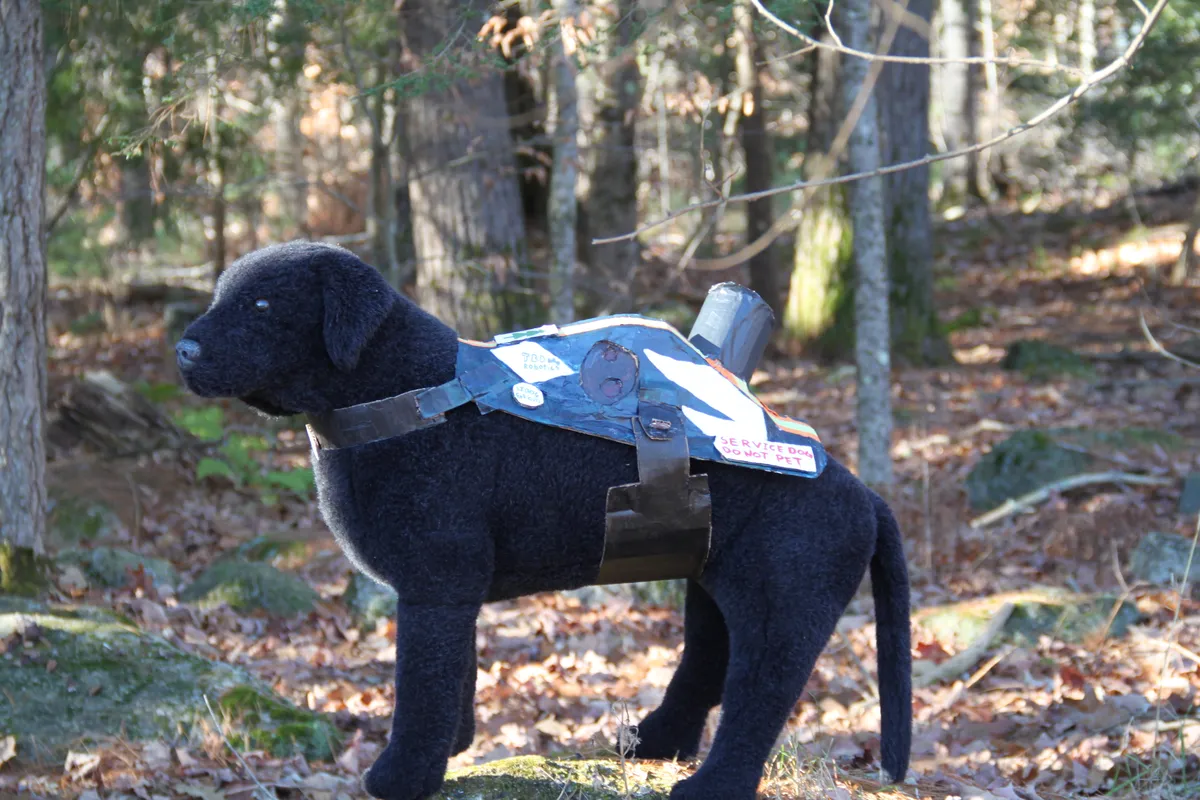
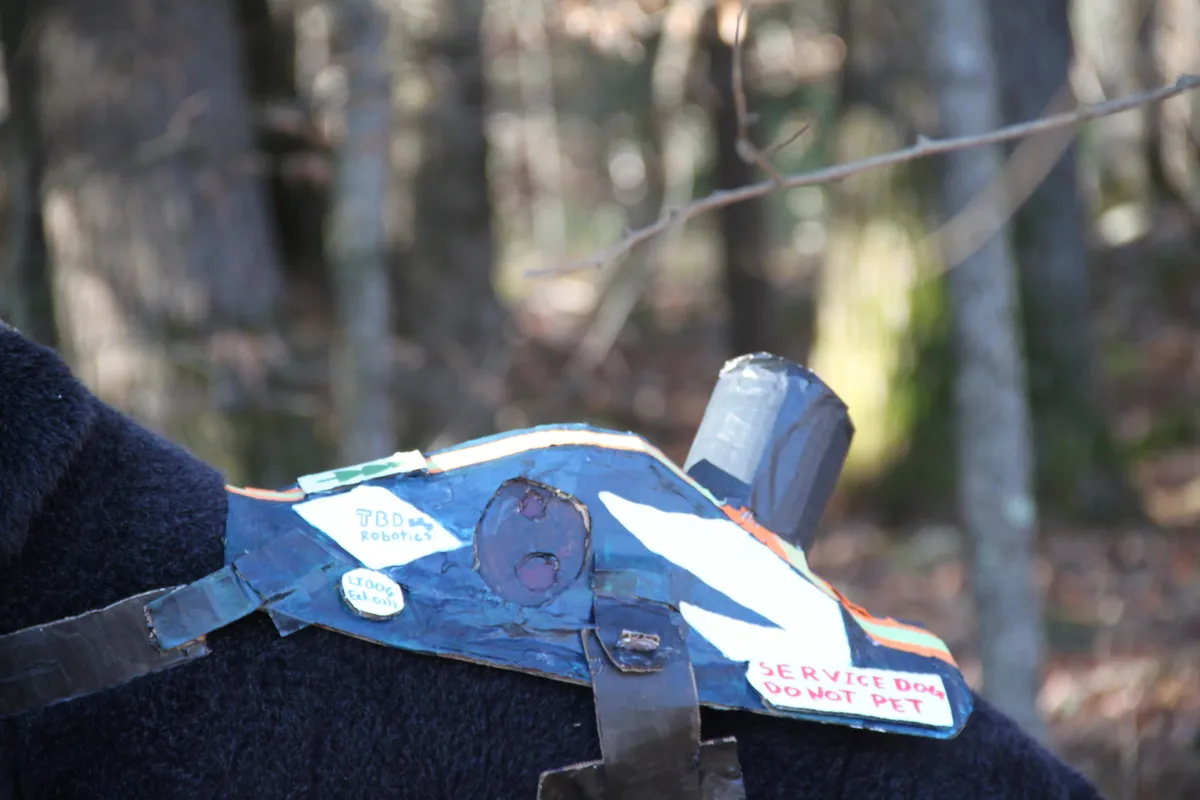
Mock-up of LiDOG, a canine-based LiDAR scanner for forestry.
Team 71229, [TBD] Robotics, would like to thank the following people for their assistance with our innovation challenge project, LiDOG, a canine-portable LiDAR system for forestry:
On the use of human-portable mobile LiDAR for forestry:
Dr Ayman Habib of Purdue University
On forestry methods, and promoting/maintaining biodiversity:
- Andrew Richley, arborist, GreenShepherdNH.com.
- Luke Beradinelli, Wildlife Habitat Forester, NH Division of Forests and Lands, NH Department of Natural and Cultural Resources.
On dog training, breeds, carrying capacity, and capability to run patterns:
- Jason Fiske, retired police officer and dog trainer.
- Josh Enoh of SitMeansSit.com dog training.
And the following research paper of similar system:
Previous |